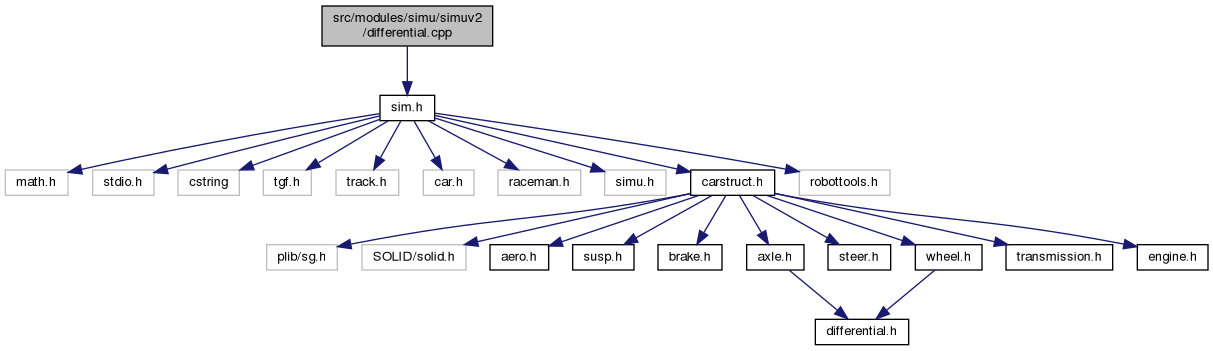
Go to the source code of this file.
◆ applyBrakeToSpinVel()
Integrate wheel/axle brake torque for one simulation step.
This helper encapsulates the common brake integration logic used in both spool and split-differential update paths.
Behavior details preserved from the original inline code:
- Brake torque opposes the current rotation sign (SIGN(spinVel)).
- If one integration step would cross through zero, the speed is clamped exactly to zero instead of changing sign.
- If speed is exactly zero and braking requests a negative step (possible because SIGN(0) is positive), the step is suppressed to keep standstill.
- Parameters
-
| [in] | spinVel | Current angular speed. |
| [in] | brkTq | Positive brake torque magnitude for this axis. |
| [in] | inertia | Effective rotational inertia used for integration. |
- Returns
- Updated angular speed after applying brake integration for dt.
Definition at line 41 of file differential.cpp.
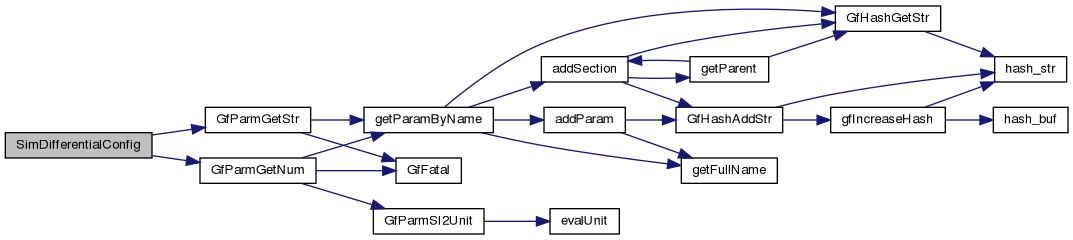
◆ SimDifferentialConfig()
| void SimDifferentialConfig |
( |
void * | hdle, |
|
|
const char * | section, |
|
|
tDifferential * | differential ) |
◆ SimDifferentialReConfig()
| void SimDifferentialReConfig |
( |
tCar * | car, |
|
|
int | index ) |
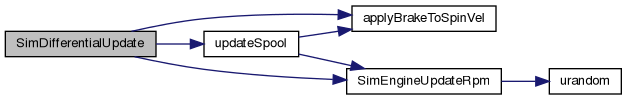
◆ SimDifferentialUpdate()
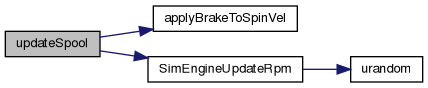
◆ updateSpool()
 1.14.0