|
| tdble | RtTrackGetWidth (tTrackSeg *seg, tdble toStart) |
| | Get the track width at the specified point.
|
| void | RtTrackLocal2Global (tTrkLocPos *p, tdble *X, tdble *Y, int flag) |
| | Calculate global coordinates from a local position relative to the given track segment (segment, toRight, toStart)The toStart position refers to the current segment, the function will not search for next segment if toStart is greater than the segment length.
|
| template<typename T> |
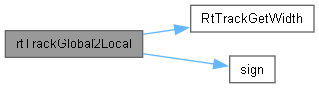
| static void | rtTrackGlobal2Local (tTrackSeg *segment, T X, T Y, tTrkLocPos *p, int type) |
| void | RtTrackGlobal2LocalD (tTrackSeg *segment, double X, double Y, tTrkLocPos *p, int type) |
| | Convert global coordinates to a local track position using double intermediates.
|
| void | RtTrackGlobal2Local (tTrackSeg *segment, tdble X, tdble Y, tTrkLocPos *p, int type) |
| | Convert global coordinates to a local track position.
|
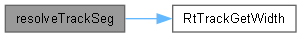
| static tTrackSeg * | resolveTrackSeg (const tTrkLocPos *p, tdble *toRight) |
| | Resolve the effective segment and rebase the lateral coordinate to it.
|
| tdble | RtTrackHeightL (tTrkLocPos *p) |
| | Returns the absolute height in meters of the road at the Local position p.
|
| tTrackSeg * | RtTrackGetSideNeighbourSeg (tTrackSeg *main, tTrackSeg *current, int tr_side) |
| | Get the neighbour segment of the given current segment.
|
| tTrackSeg * | RtTrackGetSeg (tTrkLocPos *p) |
| | Get the effective segment of the given position starting from a segment of type TR_MAIN, searching to the sides.
|
| tdble | RtTrackHeightG (tTrackSeg *seg, tdble X, tdble Y) |
| | Returns the absolute height in meters of the road at the Global position (segment, X, Y)
|
| void | RtTrackSideNormalG (tTrackSeg *seg, tdble X, tdble Y, int side, t3Dd *norm) |
| | Compute the horizontal inward border normal using the supplied segment.
|
| tdble | RtTrackSideTgAngleL (tTrkLocPos *p) |
| | Used to get the tangent angle for a track position The angle is given in radian.
|
| void | RtTrackSurfaceNormalL (tTrkLocPos *p, t3Dd *norm) |
| | Used to get the normal vector of the road (pointing upward).
|
| tdble | RtGetDistFromStart (tCarElt *car) |
| | Get distance along the track from the start/finish line.
|
| tdble | RtGetDistFromStart2 (tTrkLocPos *p) |
| | Get distance along the track from the start/finish line.
|
| int | RtDistToPit (struct CarElt *car, tTrack *track, tdble *dL, tdble *dW) |
| | Get the distance to the pit stop.
|
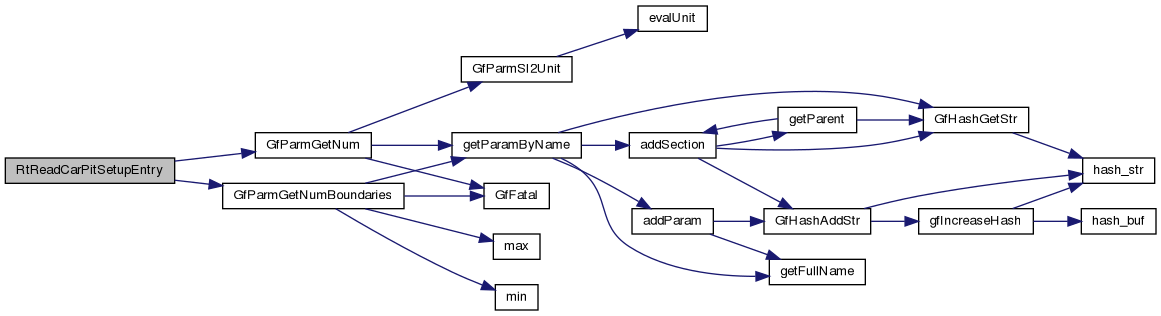
| static void | RtReadCarPitSetupEntry (tCarPitSetupValue *v, const char *path, const char *key, void *hdle, bool minmaxonly) |
| void | RtInitCarPitSetup (void *hdle, tCarPitSetup *s, bool minmaxonly) |
| | Initialize tCarPitSetup from data in parameter set given in handle hdle.
|
| void | RtGetCarPitSetupFilename (rtCarPitSetupType type, int robidx, const char *carname, const char *trackname, char *filename, const int len) |
| | Compose filename from given strings.
|
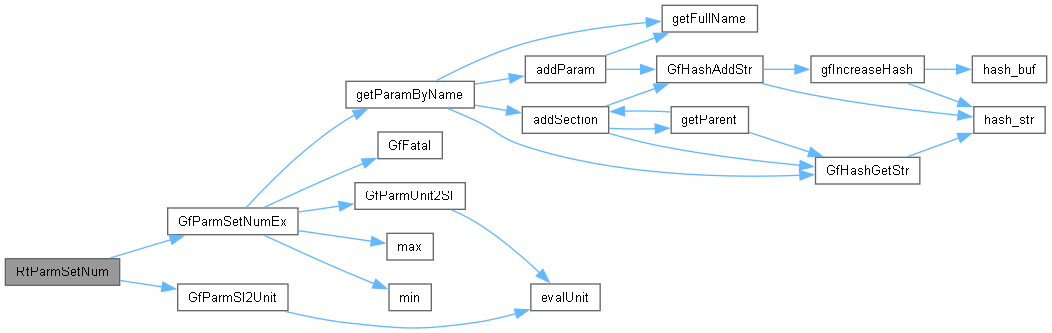
| static void | RtParmSetNum (void *hdlesetup, const char *path, const char *key, const char *unit, tCarPitSetupValue *v) |
| | Robottool internal: Set parameter if min != max, save as well min and max values.
|
| void | RtSaveCarPitSetupFile (void *hdlecar, tCarPitSetup *s, const char *filepath, const char *carname) |
| | Save adjustable setup entries to a file, merging them with hdlecar's restrictions.
|
| void | RtSaveCarPitSetup (void *hdlecar, tCarPitSetup *s, rtCarPitSetupType type, const char *modulename, int robidx, const char *trackname, const char *carname) |
| | Save a custom setup in the robot's local setups directory.
|
| bool | RtCarPitSetupExists (rtCarPitSetupType type, const char *modulename, int robidx, const char *trackname, const char *carname) |
| | Checks if a specific car setup is available.
|
| bool | RtLoadCarPitSetupFilename (void *hdlecar, const char *filepath, tCarPitSetup *s, bool minmaxonly) |
| | Load a custom setup and merge its entries with hdlecar's restrictions.
|
| bool | RtLoadCarPitSetup (void *hdlecar, tCarPitSetup *s, rtCarPitSetupType type, const char *modulename, int robidx, const char *trackname, const char *carname, bool minmaxonly) |
| | Load a custom setup from the robot's local setups directory.
|
| void * | RtLoadOriginalCarSettings (const char *carname) |
| | Gets a handle to a parameter file containing the original TORCS car setup, that means the car setup merged with the cars category setup.
|
| bool | RtInitCarPitSetupFromDefault (tCarPitSetup *s, const char *carname) |
| | Initialize the given tCarPitSetup with the original TORCS setup, that means the car setup merged with the cars category setup.
|
| void * | RtParmReadSetup (rtCarPitSetupType type, const char *modulename, int robidx, const char *trackname, const char *carname) |
| | Load a custom car setup file for a given robot, car, track and session (race, practice, qualifying, ...) type.
|
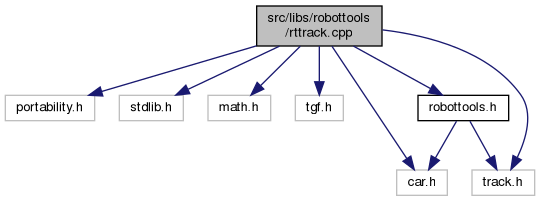
Common functions for robots.
- Author
- Bernhard Wymann, Eric Espie
Definition in file rttrack.cpp.
 1.14.0